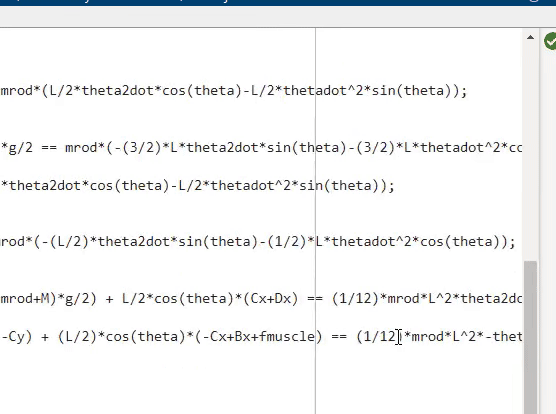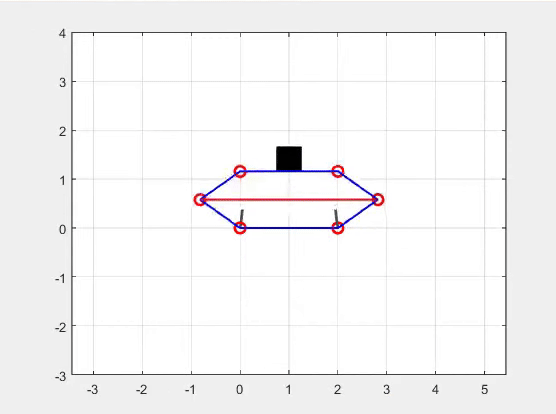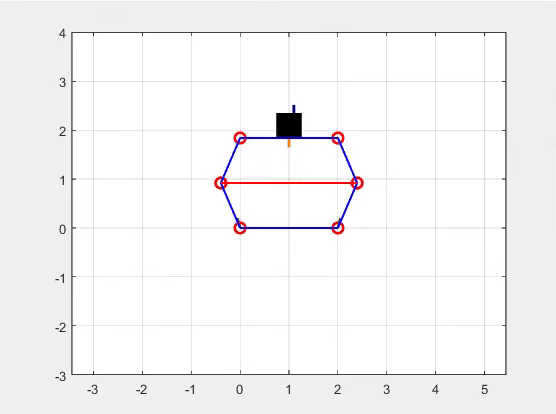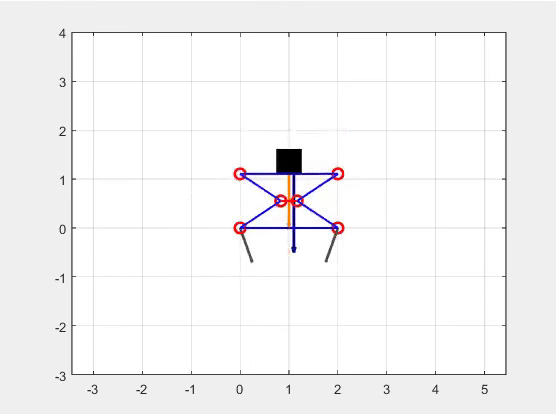
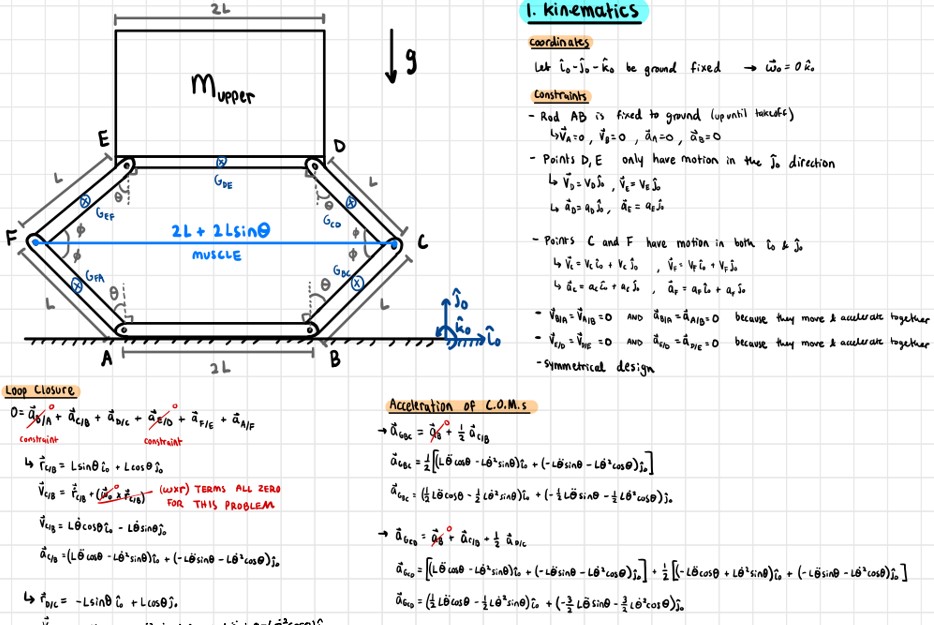
As part of the final project of my dynamics course, student were tasked with designing a jumping mechanism with lingae members and muscles which apply a constant force.
Using vector derivatives and Newtonian law, the project require for the derivation of the equations of motions of our design. I received inspiration from my proffessor when
he mentioned that a completed set of equations can model a system in it's entierty. I spent the next 2 days exploring MATLAB's powerful graphing capabilities in hopes of
bringing visuals to my design. Making use of the symbolic toolbox and creating my own animation function, I was able to create a visual representation of my final project.
Above are some of the tedious written calculations for the assignment itself. Translating it to MATLAB and ensuring that every variable was where its suppose to be proved to be even more challenging.